012026
Ground-Up 5" Quadcopter Build
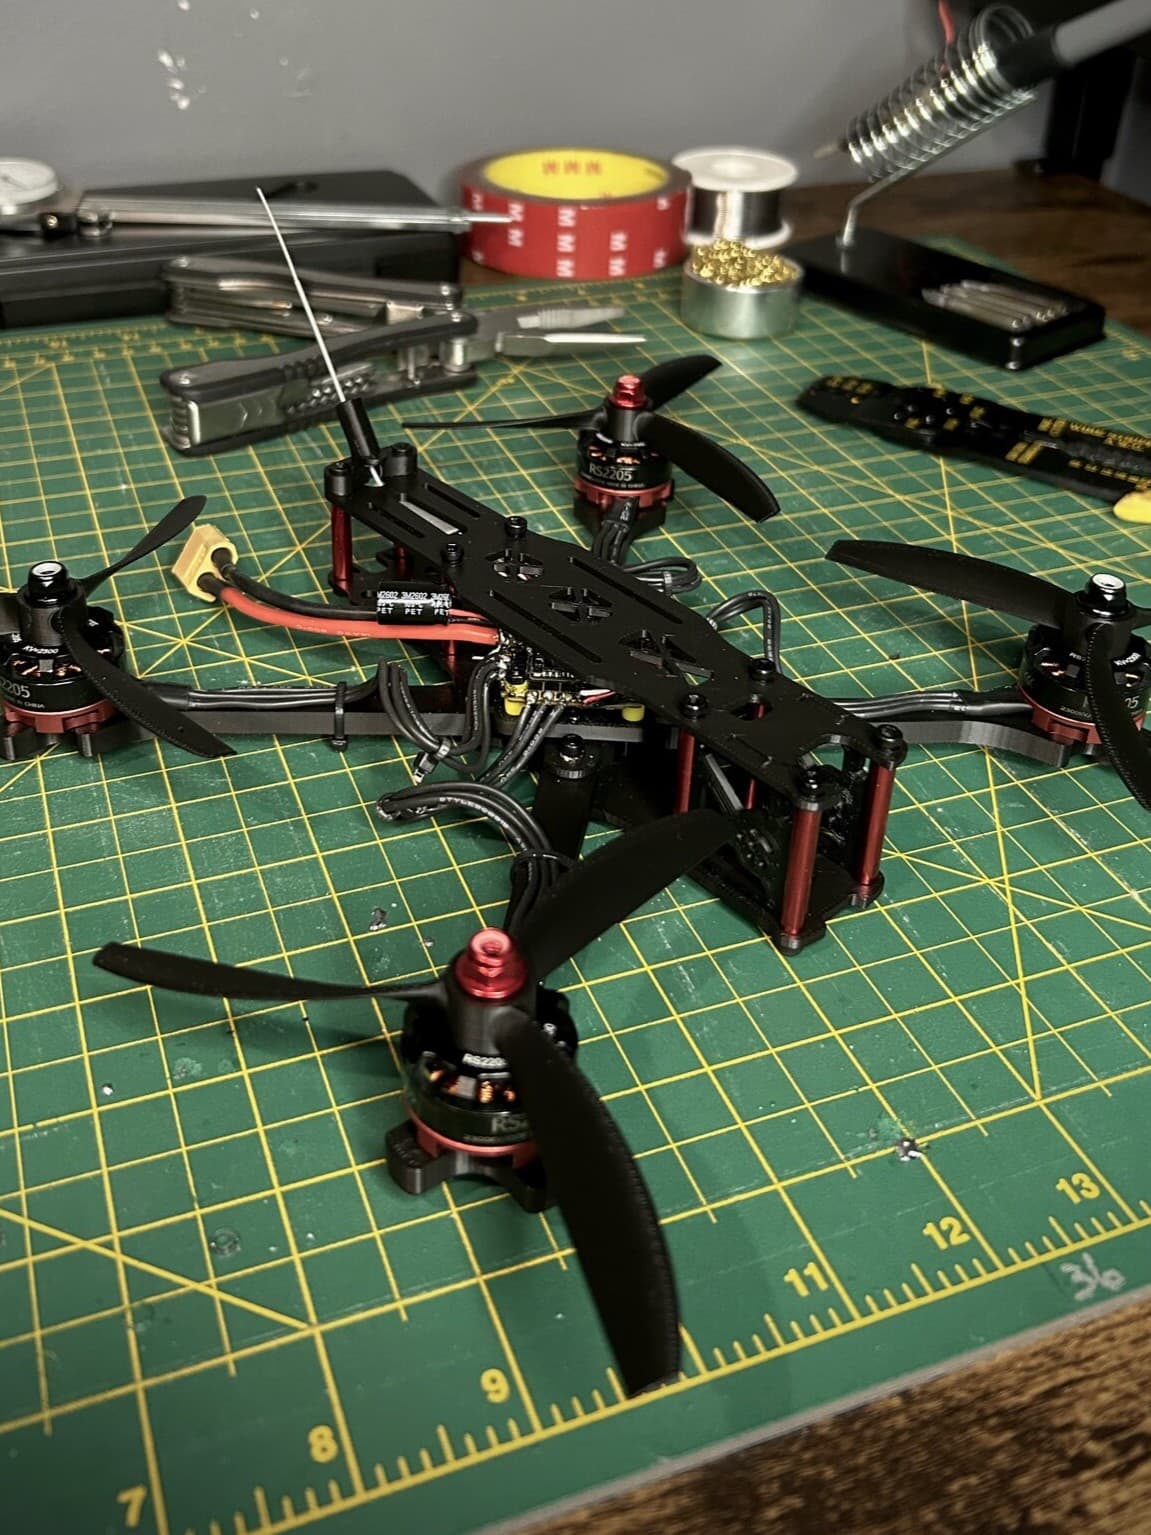
·Design + PID tuning- Built a 5-inch racing-style quadcopter end-to-end — starting from a 5" X-frame in CAD, then designing my own propellers and a custom flight-controller adapter to fit the electronics stack.
- 3D-printed every frame component myself, iterating on fit and stiffness until the airframe held up to flight loads.
- Selected and integrated the electronics: SpeedyBee F405 AIO flight controller, RS2205 brushless motors, FlySky radio link, and 3S 2200mAh LiPo packs.
- Soldered every joint on the airframe myself — ESCs to motors, power distribution, receiver, and flight-controller harness — then configured and PID-tuned it in Betaflight to hit stable hover and controlled flight.
- Crashed it, tuned it, flew it — each crash sent me back to the printer, the soldering iron, or Betaflight. Those iterations are what turned the airframe from wobble to stable hover.
sound on
BetaflightPID TuningSolidWorks3D Print